Hands-On Workshops
Workshops We Offer for SamaraBoT
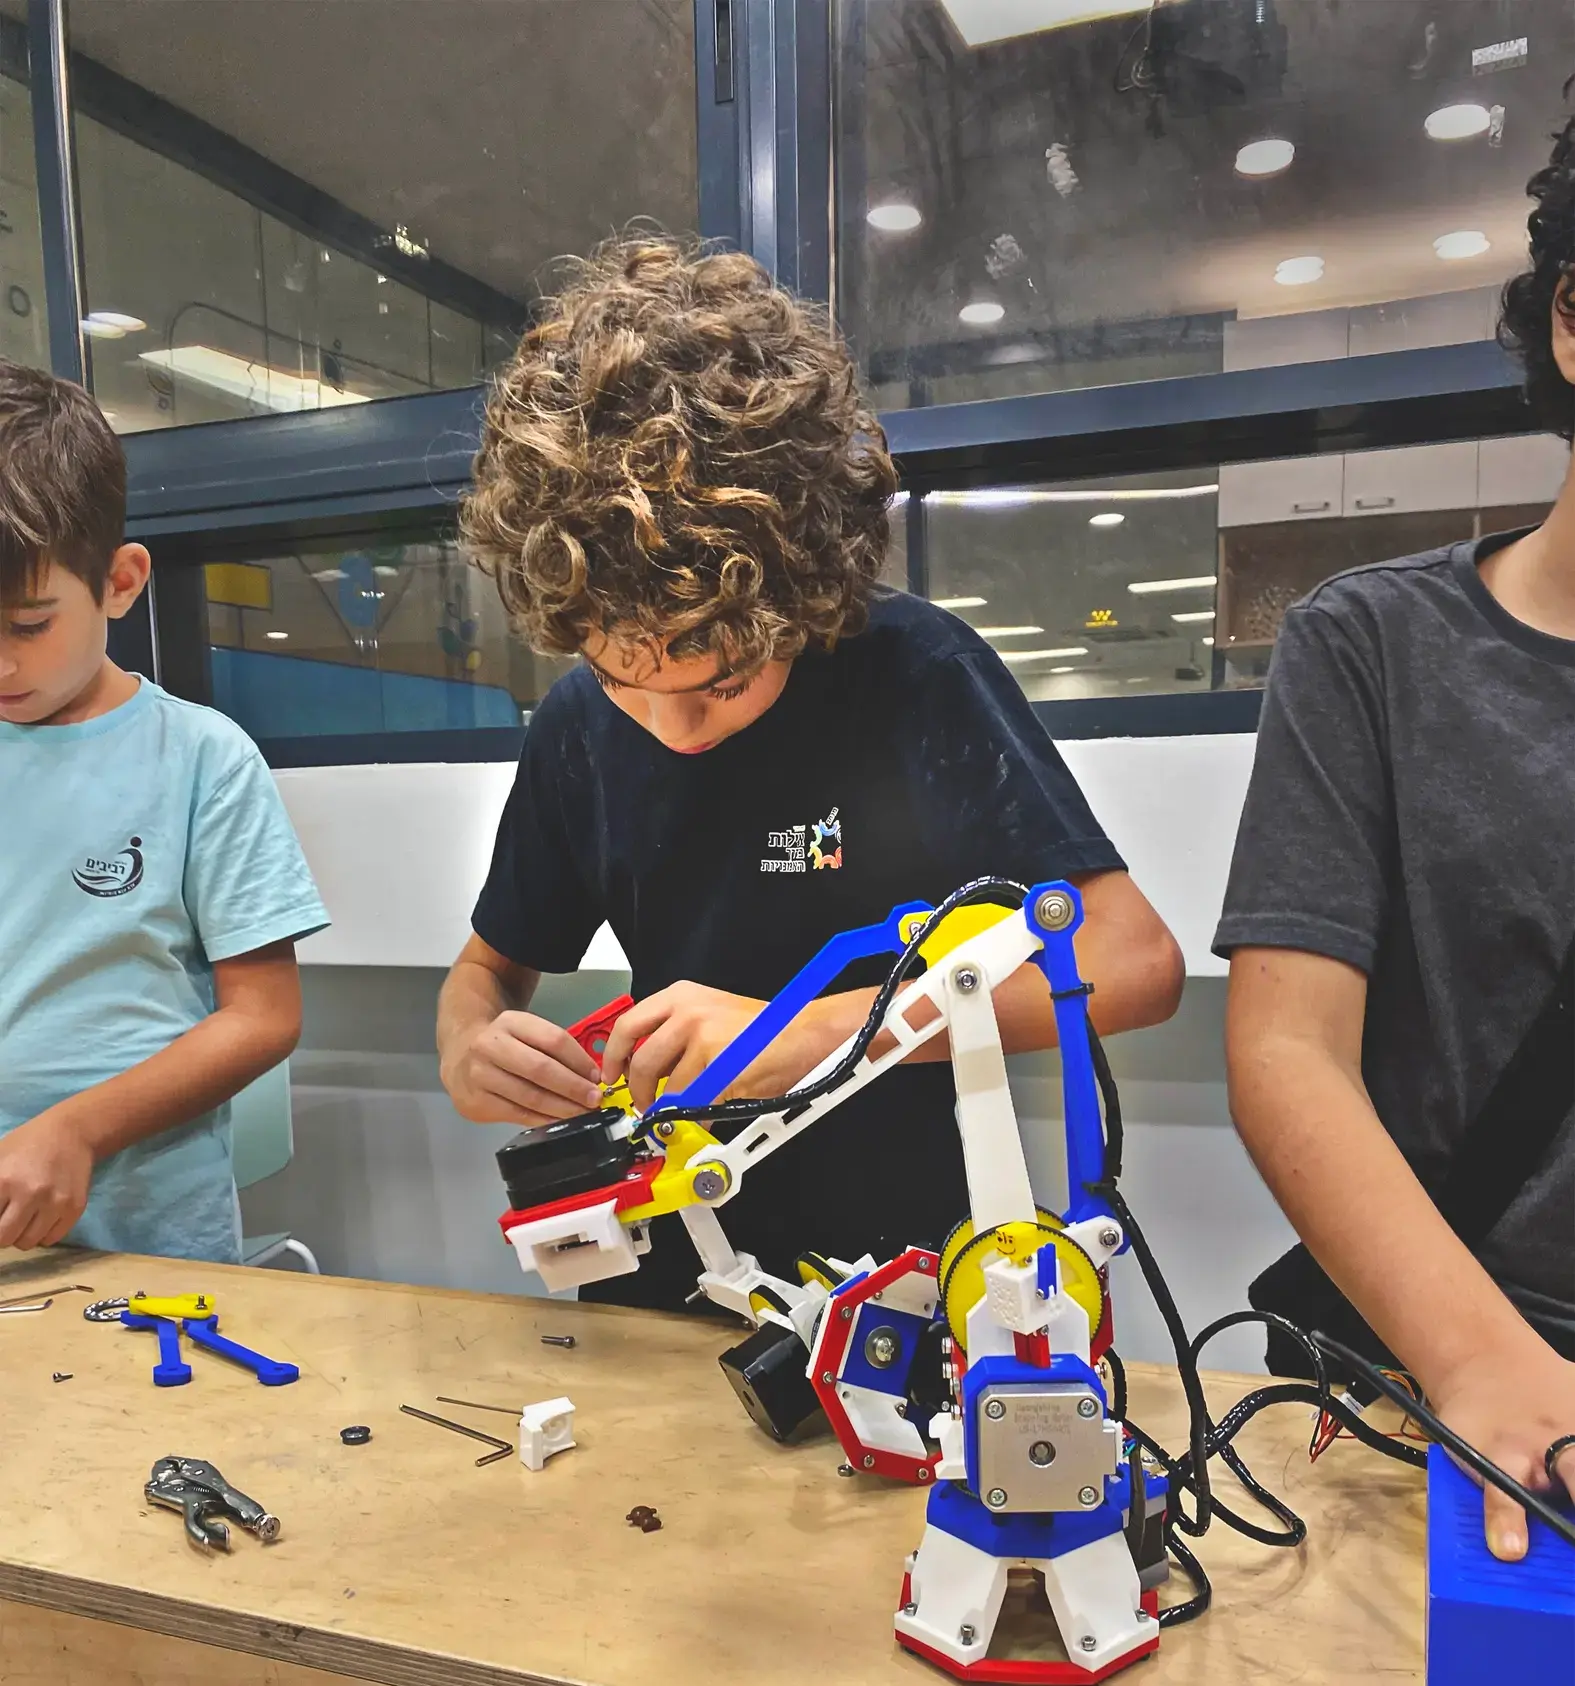
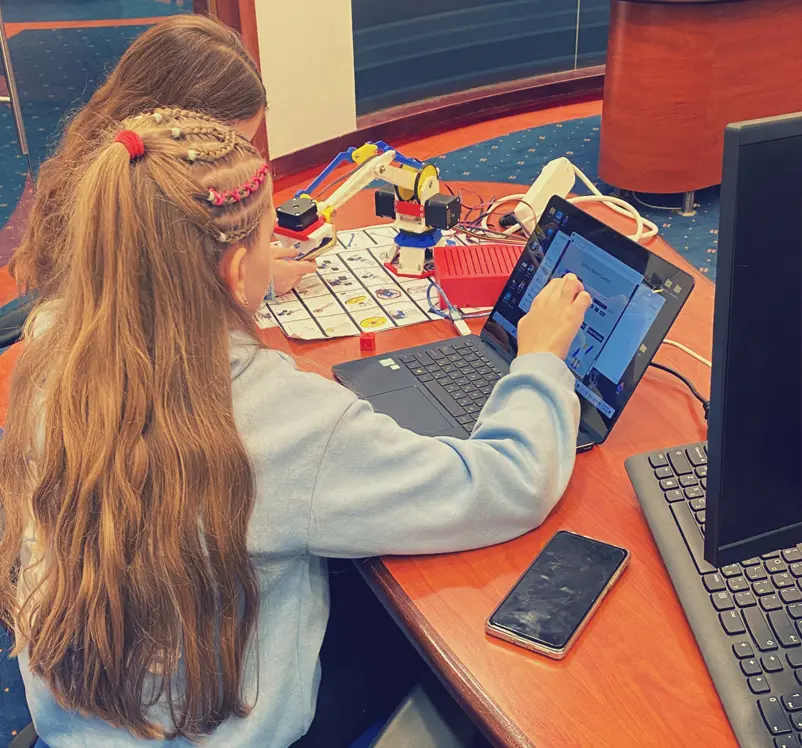
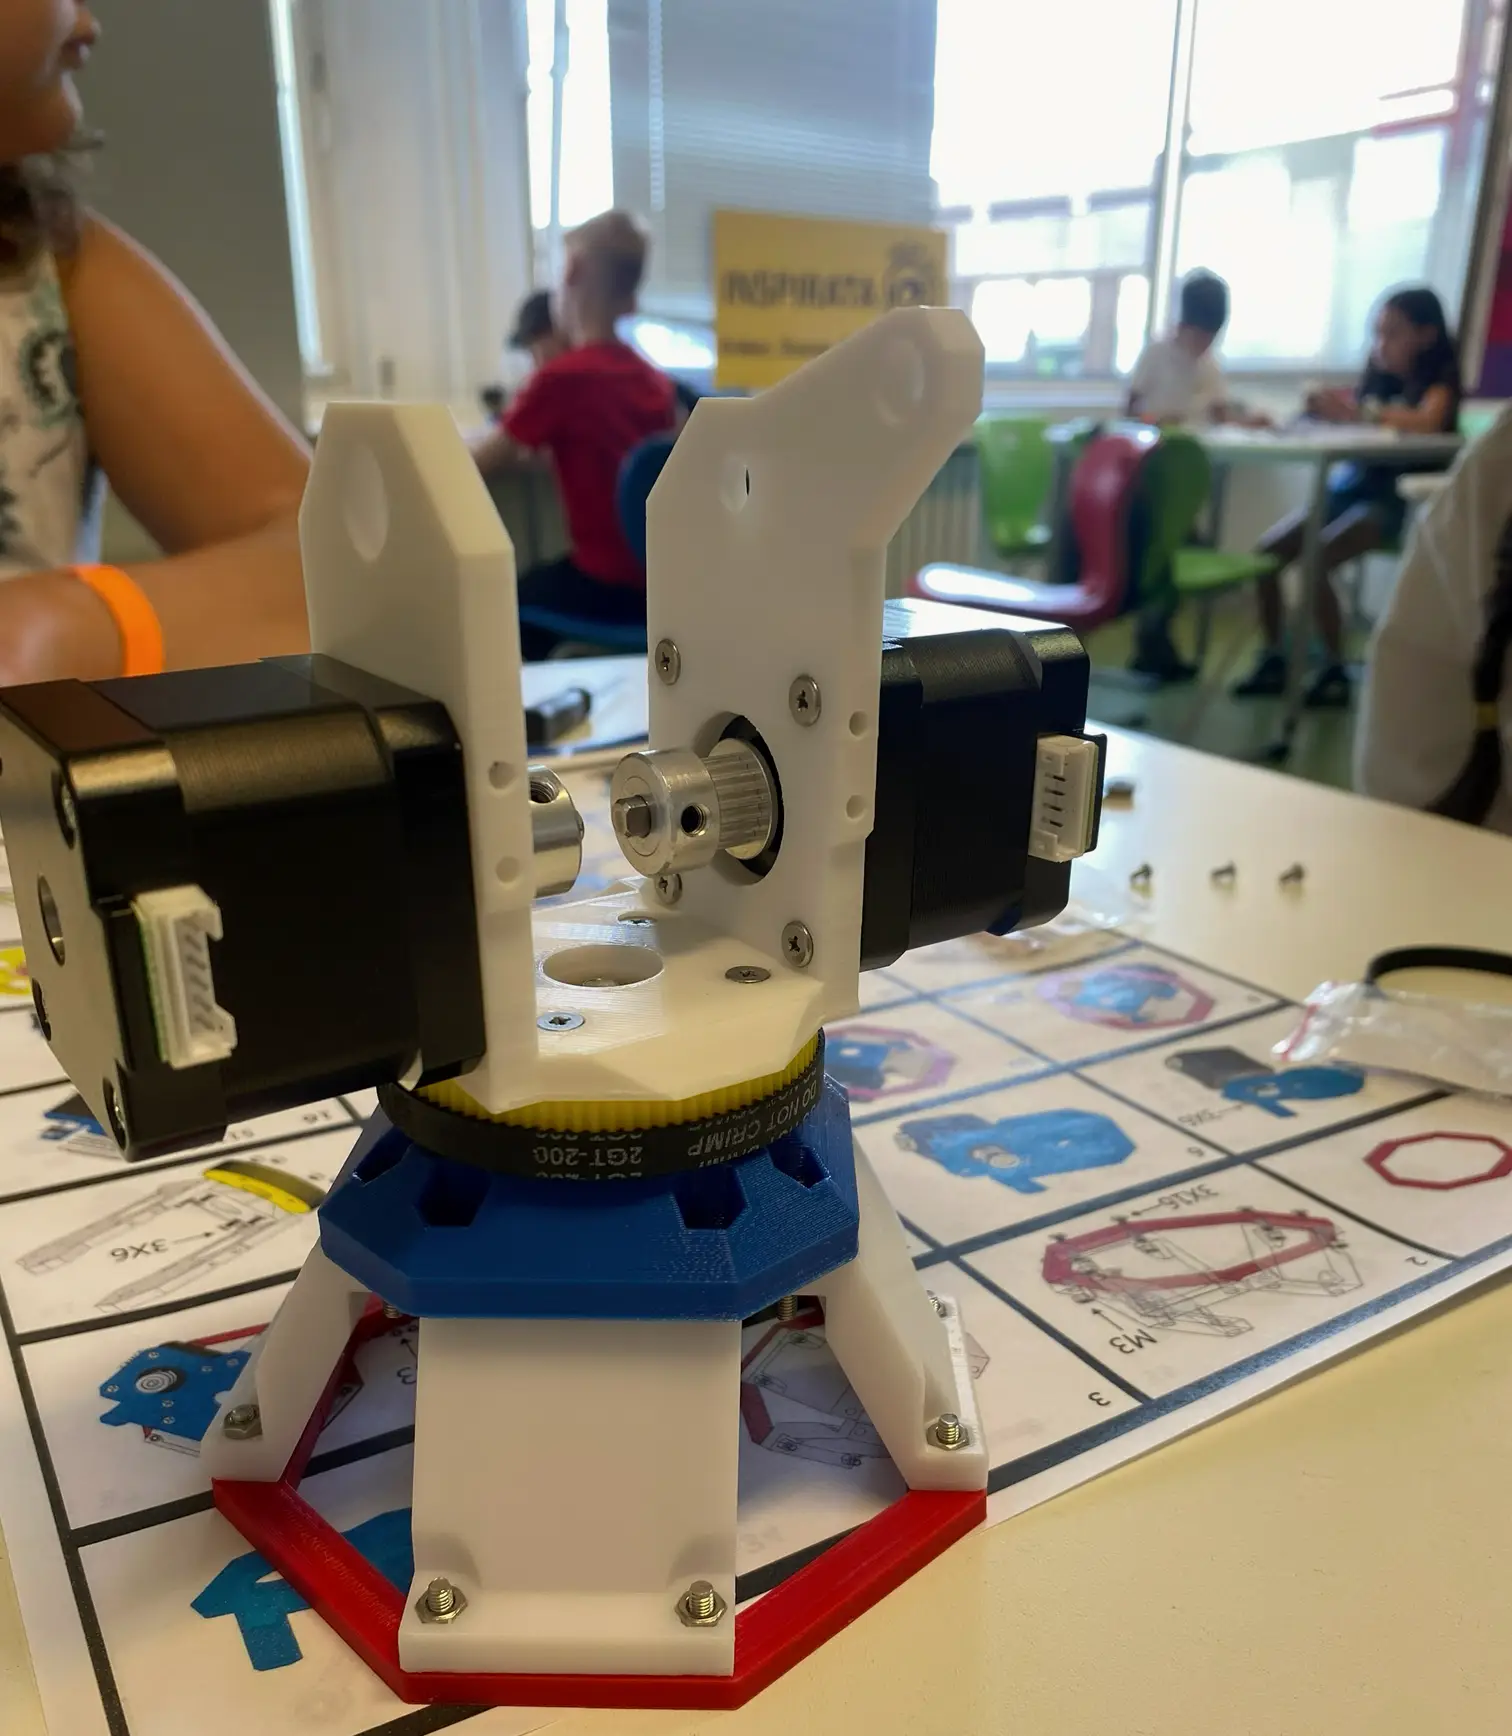
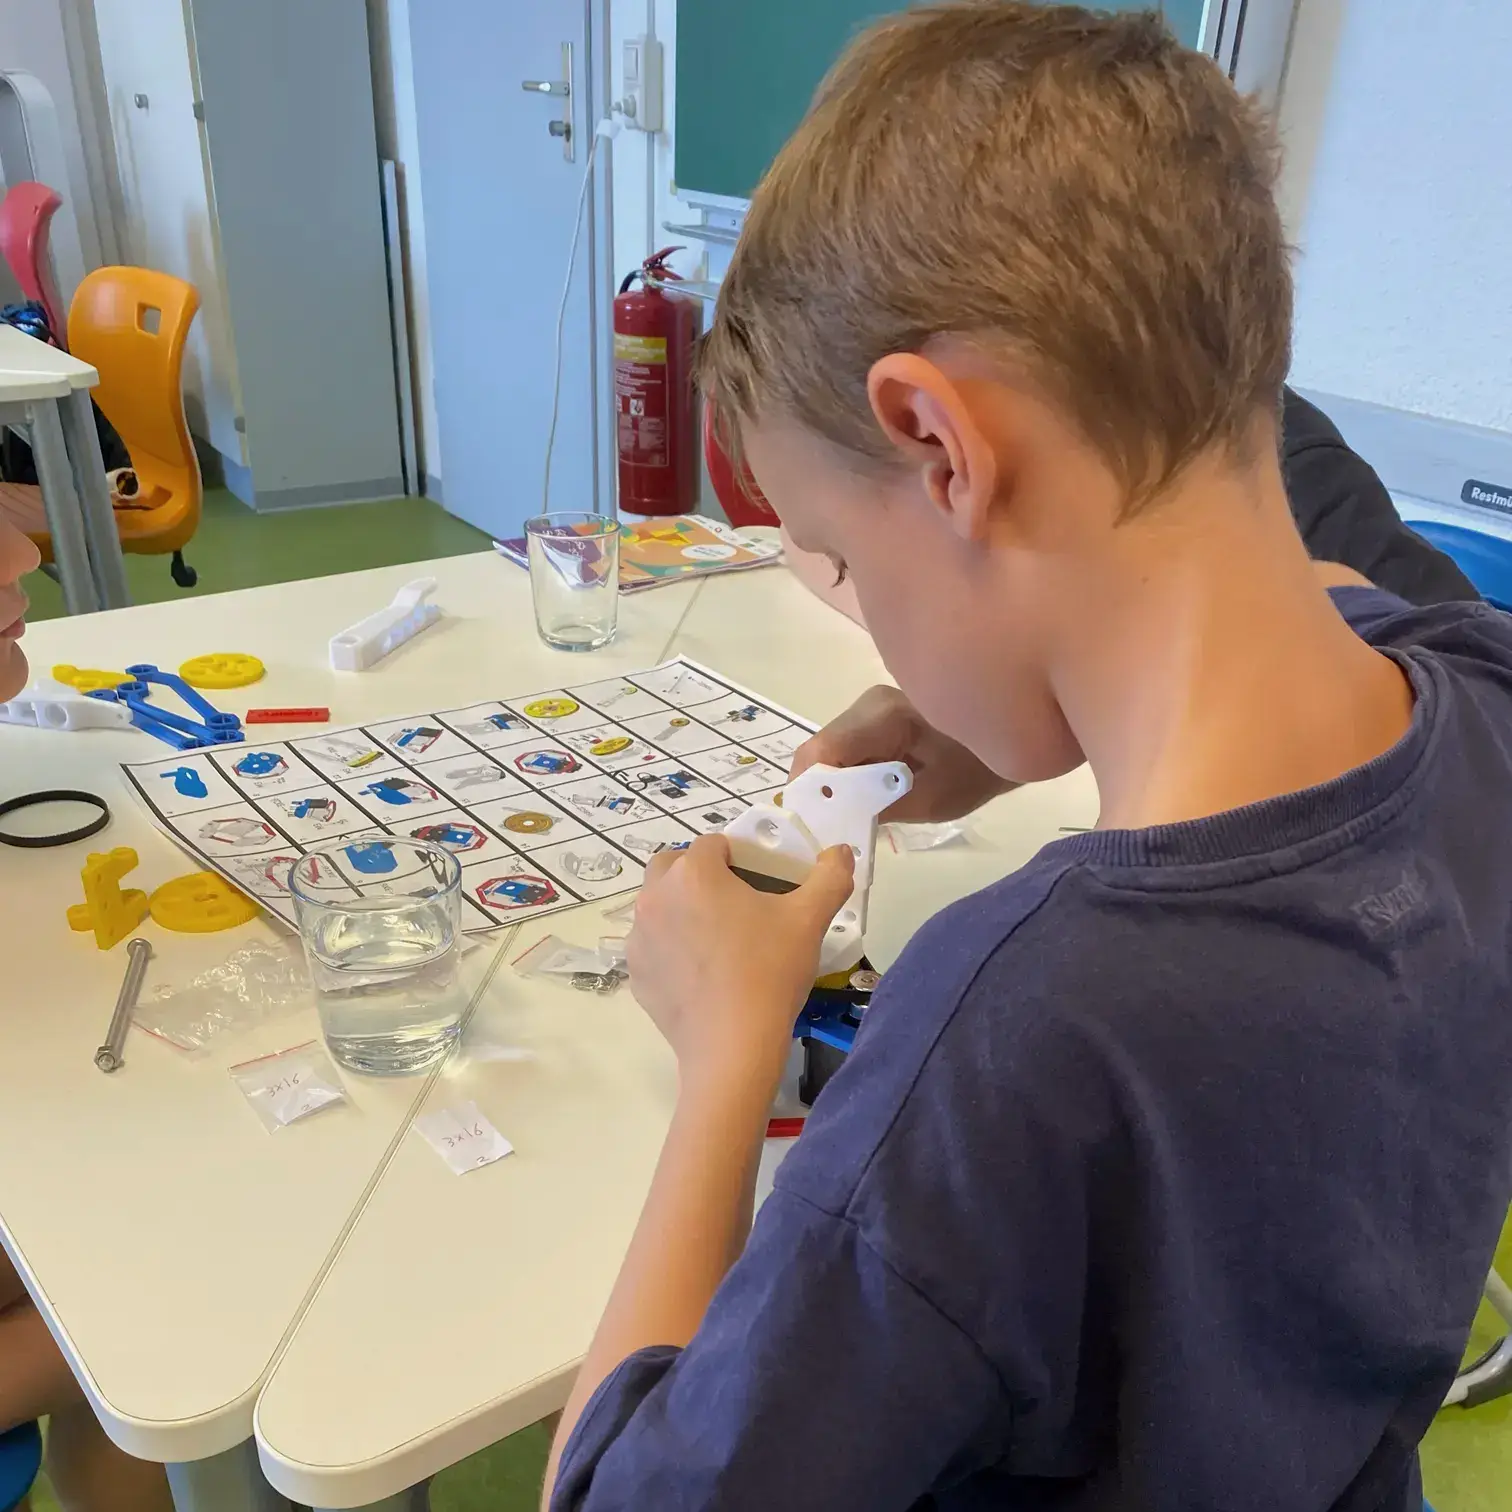
Connect the stepper motors, the IR sensor, and the gripper motor to the control board, and see how a circuit becomes motion.
Plug in over USB, pick the port, and let the SamaraBoT app home every axis automatically before it's ready to move.
Move each axis and the gripper by hand, with built-in limits so the arm can't collide with itself.
An infrared sensor queues up parts automatically, with adjustable spacing for lining them up on a conveyor.
Every action is mirrored as real code in a live window, and students can type and run their own commands.
On connect, the app walks every axis to its home position before handing control to the student.
SamaraBoT keeps growing. Here's what our team is working on right now to take the arm from a teaching tool to a full desktop fabrication robot.
Swapping the gripper for a pen holder so the arm can draw shapes and handwriting straight from code.
Adding an extruder head so SamaraBoT can lay down filament and print small parts on its own.
Mounting a laser module to engrave and cut designs into wood, controlled from the same app.