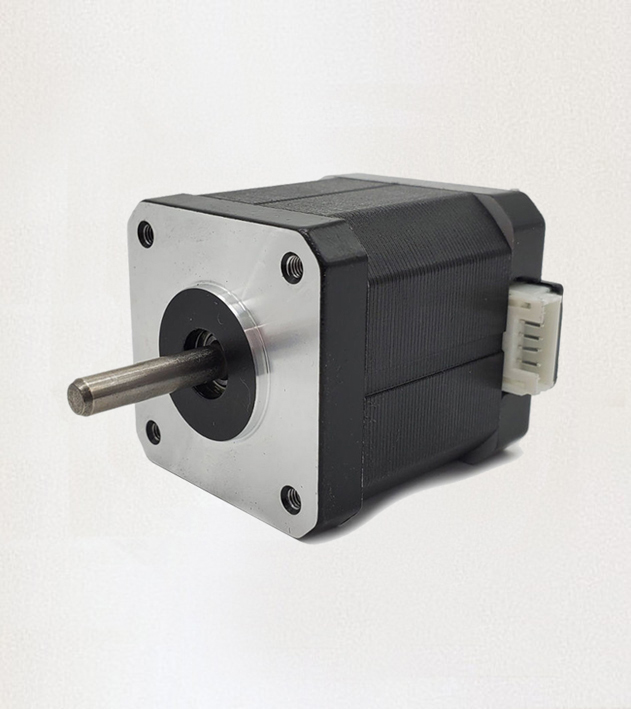
How does a stepper motor move a robotic arm? Inside the SamaraBoT joints
Every time a SamaraBoT arm moves to a position, picks up a part, or places it on a conveyor belt, a small device is quietly doing the hard work: the stepper motor. In this article we look inside the SamaraBoT joints and explain, in plain language, what a stepper motor is, how it moves the […]
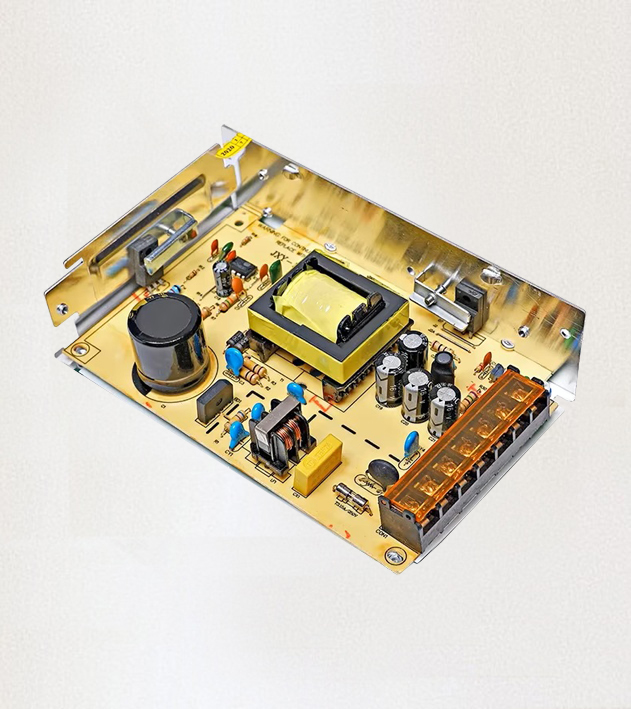
How does a robotic arm get its power? A beginner’s guide to the SamaraBoT power supply
Every time the SamaraBoT arm lifts a part, rotates a joint, or closes its gripper, it needs energy. That energy comes from a single, small power supply that sits quietly on the desk next to the robot. In this article we explain, in plain language, what the power supply does, why it matters, and what […]
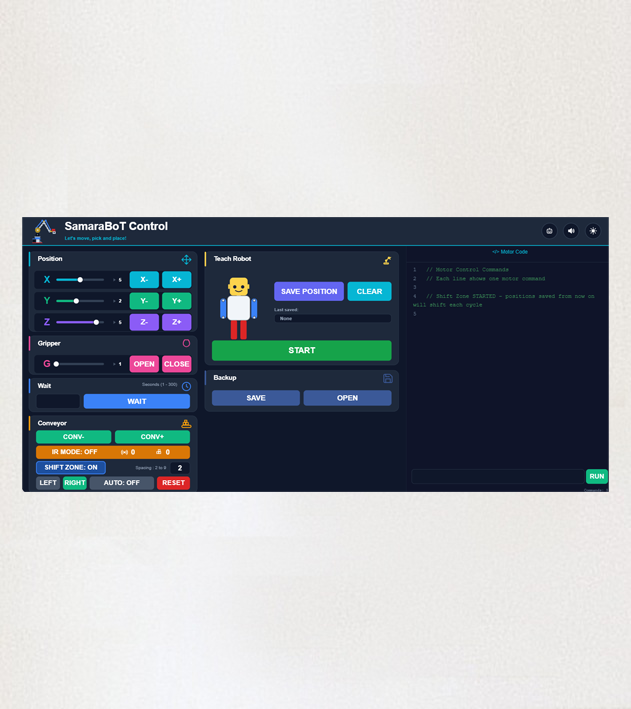
Inside the SamaraBot Control app: how a student commands a robot
Every SamaraBoT robotic arm comes with a companion: a small piece of software called the SamaraBot Control app. It runs on a normal computer, connects to the robot through a USB cable, and gives the student complete control over every joint. Without the app, the robot would be silent and still. With it, the arm […]
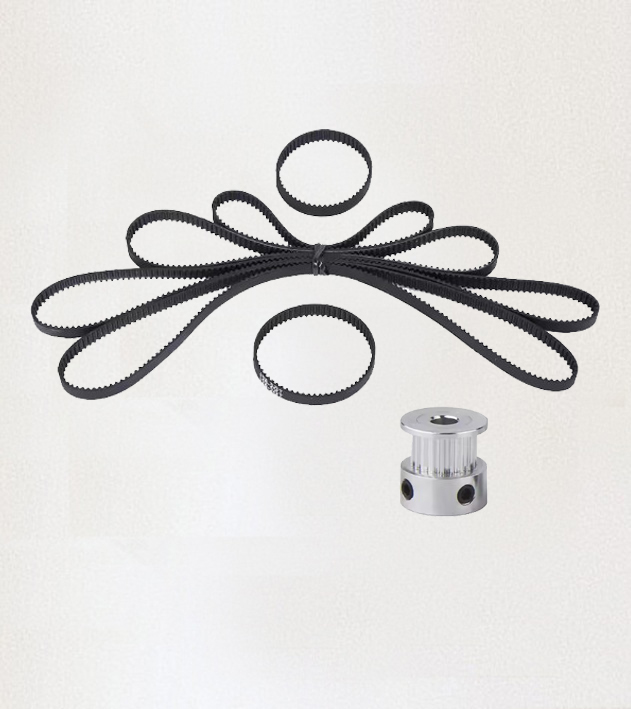
Why SamaraBoT uses timing belts (and how they move the robot)
Every time a SamaraBoT robotic arm moves from one saved position to the next, a small black belt quietly turns inside the joint. It looks simple — a loop of rubber with teeth on the inside — but without it, the motor could not move the arm at all. That belt is called a timing […]
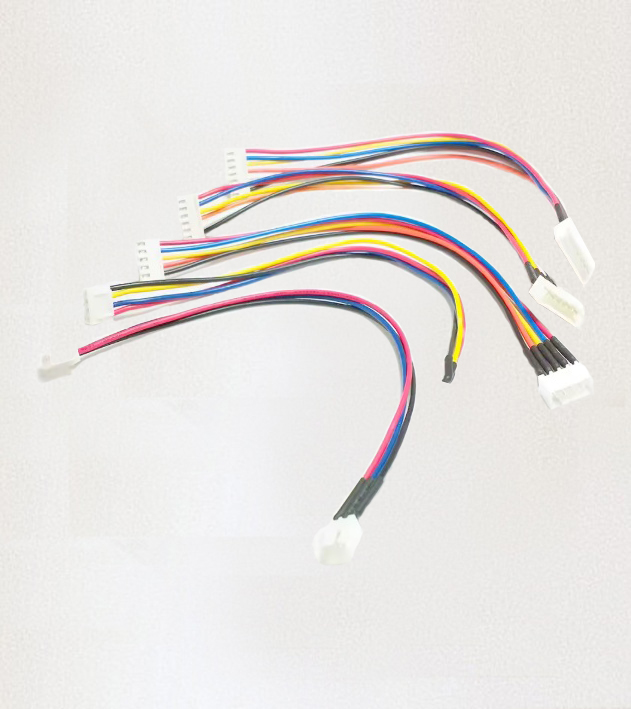
Why SamaraBoT uses jumper wires (and why color matters)
Every SamaraBoT robotic arm contains motors, a control board, sensors, and a power supply. But none of these parts can talk to each other on their own. Between them runs a small, colorful web of cables that carries every signal, every command, and every bit of power through the robot. Those cables are called jumper […]
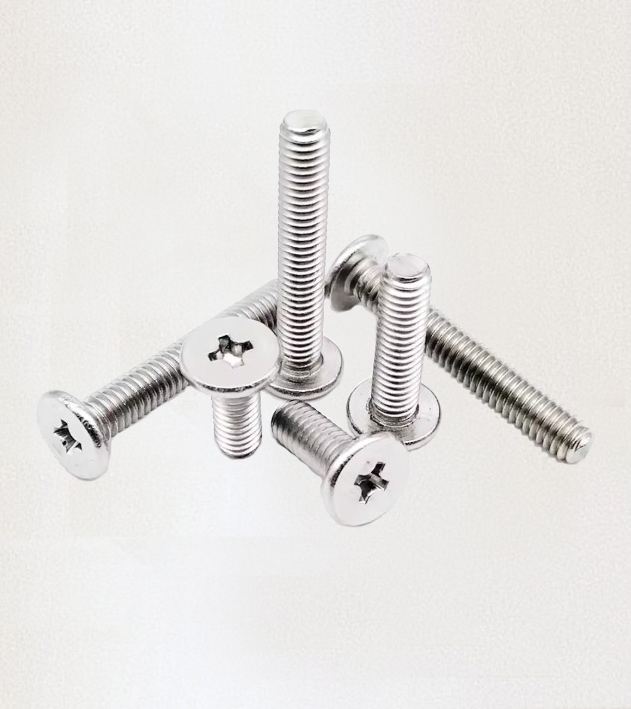
Why SamaraBoT uses stainless steel screws (and why the small ones matter)
Every time you look at a SamaraBoT robotic arm, you see the motors, the wires, the gripper, and the bright blue arms that move. What you do not see is the small army of screws holding everything together. Those screws are not just any screws. They are stainless steel screws — and without them, the […]
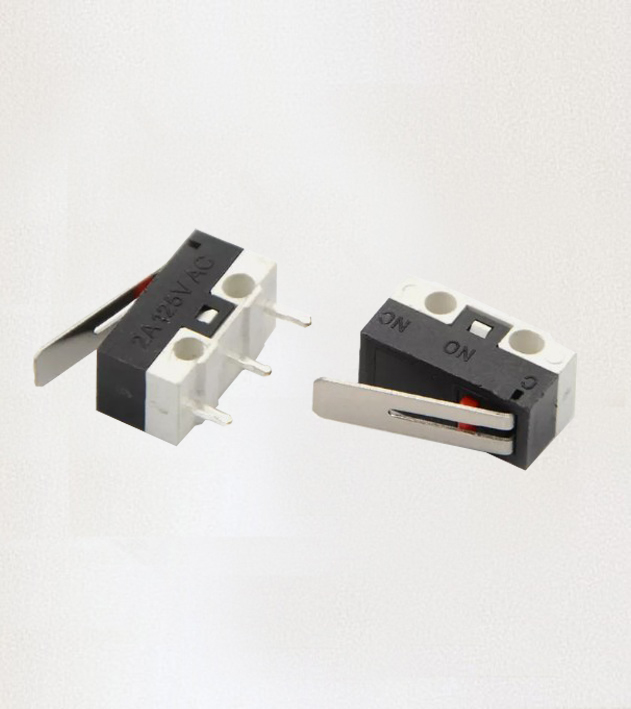
Micro limit switch: how a robotic arm knows when to stop
Inside every SamaraBoT joint, there is a small device that does something very simple but extremely important: it tells the robot when to stop. It is called a micro limit switch. It is small, mechanical, and completely silent until it is needed. But without it, the robotic arm would not know where it is, and […]
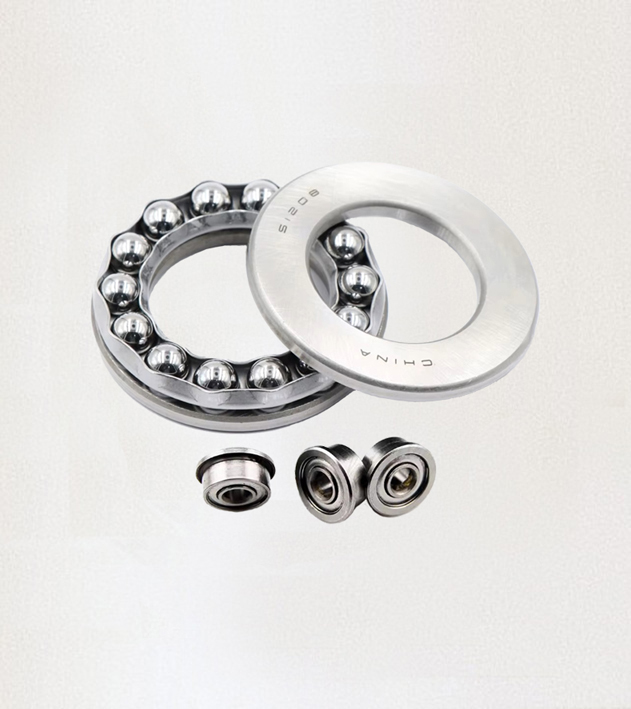
How Do Bearings Let a Robotic Arm Move So Smoothly? Inside the SamaraBoT Joints
Every joint in a robotic arm has to rotate. But two pieces of metal rubbing directly against each other would grind, heat up, and wear out within hours. That is where a bearing comes in. A bearing is a small mechanical component that sits between two moving parts. Instead of letting the surfaces slide against […]